4th Workshop on
Learning Effective Abstractions for Planning (LEAP)
CoRL 2026 · Nov 12, 2026 · JW Marriott, Room 306 · Austin, TX, USA
Complex long-horizon and sparse reward robotics tasks are challenging for scaling end-to-end learning methods. By contrast, planning approaches have shown great potential to handle such complex tasks effectively. One of the major criticisms of planning-based approaches has been the lack of availability of accurate world models (aka abstractions) to utilize.
There has been a renewed interest in using learning-based approaches to learn symbolic representations that support planning. However, this research is often fragmented into disjoint sub-communities such as task and motion planning, reinforcement learning (hierarchical, model-based), planning with formal logic, planning with natural language (language models), and neuro-symbolic AI. As in previous years, LEAP will bring together researchers from disparate subfields to discuss how we can combine learning, planning, and abstractions to solve increasingly complex long-horizon and sparse-reward robotics tasks.
As in prior editions, the workshop continues to engage with the foundational questions that have defined LEAP since its inception:
While the questions above ground the workshop, our key attention this year is deliberately focused on two specific, concrete, and timely challenges in learning abstractions for planning.
Programs and code offer a uniquely powerful substrate for abstraction in robot planning. They are compositional, verifiable, reusable, and directly executable, and they interface naturally with modern foundation models that can read, write, and edit code. We are eager to explore and discuss when and how code is the right abstraction for robot decision-making, as well as to identify its limitations:
Learned world models promise abstractions of environment dynamics that can be searched, simulated, and planned over. We want to examine what makes a world model a good abstraction for planning (rather than merely for prediction), and how planning can be performed in, on top of, or adjacent to such models:
We solicit papers on the following topics:
Congratulations to the winners of the LEAP 2026 Best Paper Awards!
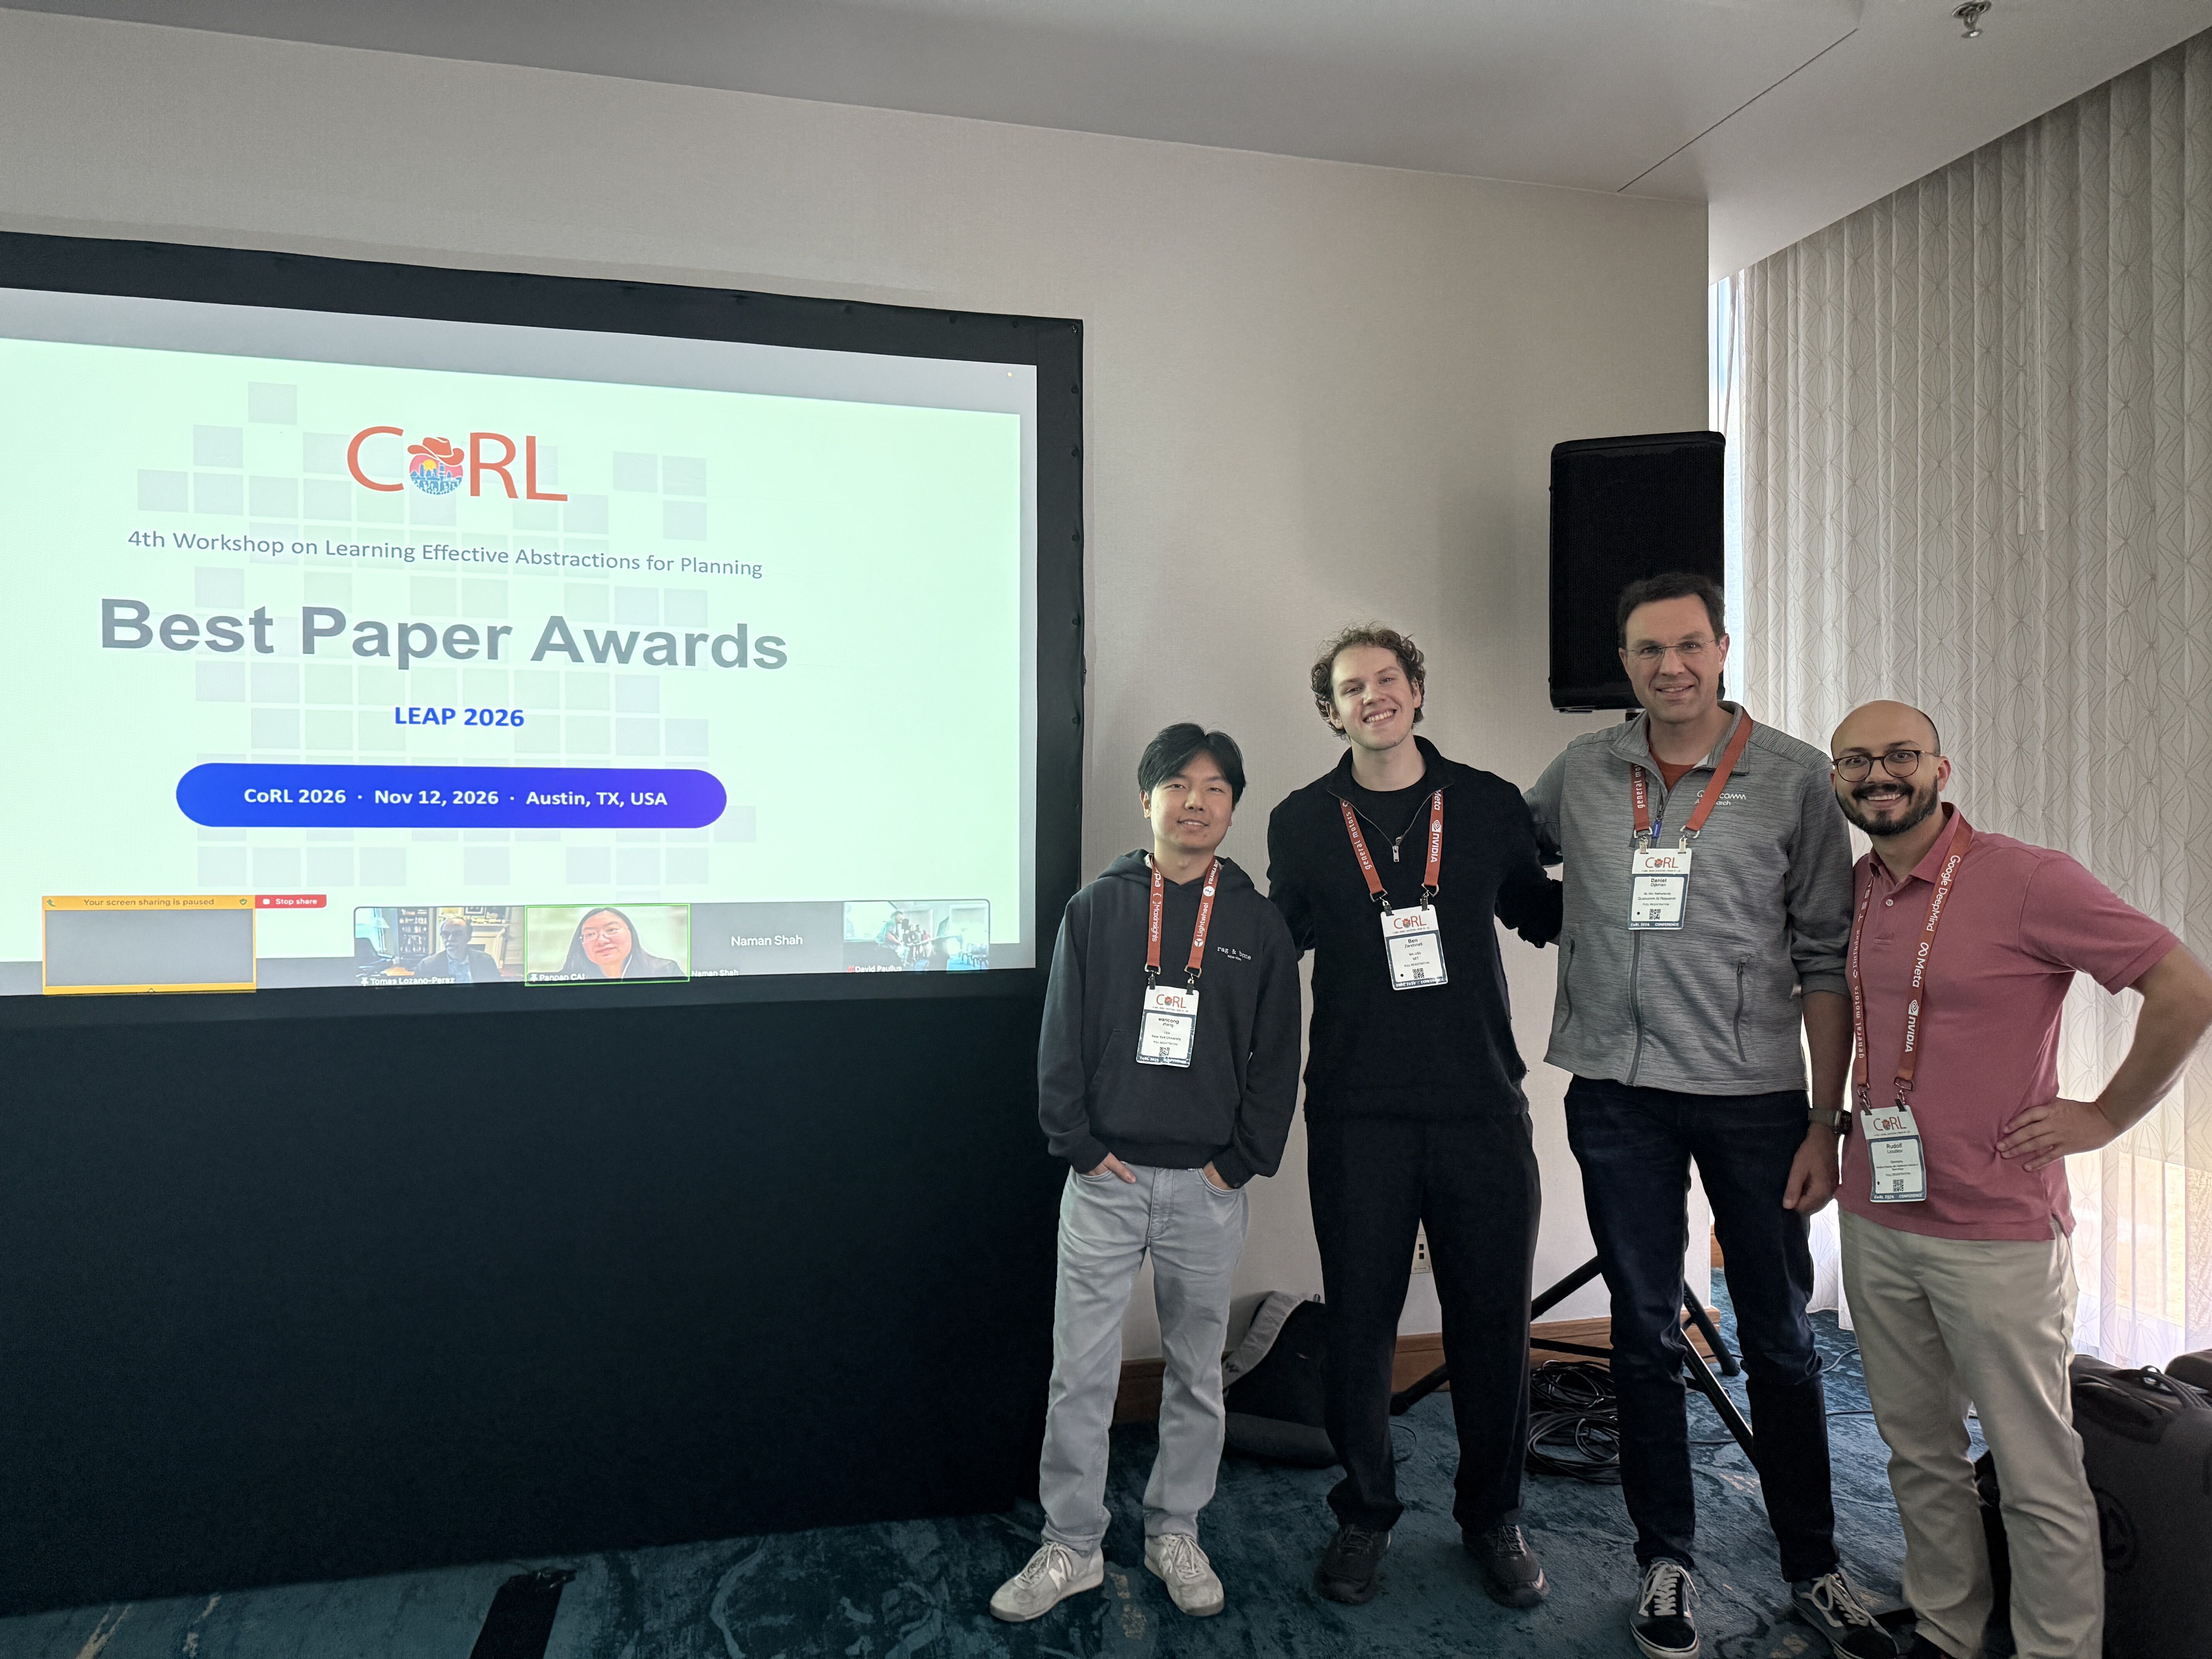
LEAP 2026 Best Paper Award presentation at CoRL 2026 in Austin, TX.
Location: JW Marriott, Room 306
| Time | Session |
|---|---|
| 8:30 – 8:35 | Opening Remarks |
| 8:35 – 9:05 |
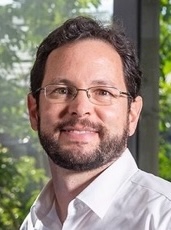
Invited Talk 1 (25 min + 5 min Q&A)
Fabio Ramos
(Nvidia & U. Sydney)
Talk Title: “Generalizing Task and Motion Planning for
Agentic Systems”
|
| 9:05 – 9:35 |
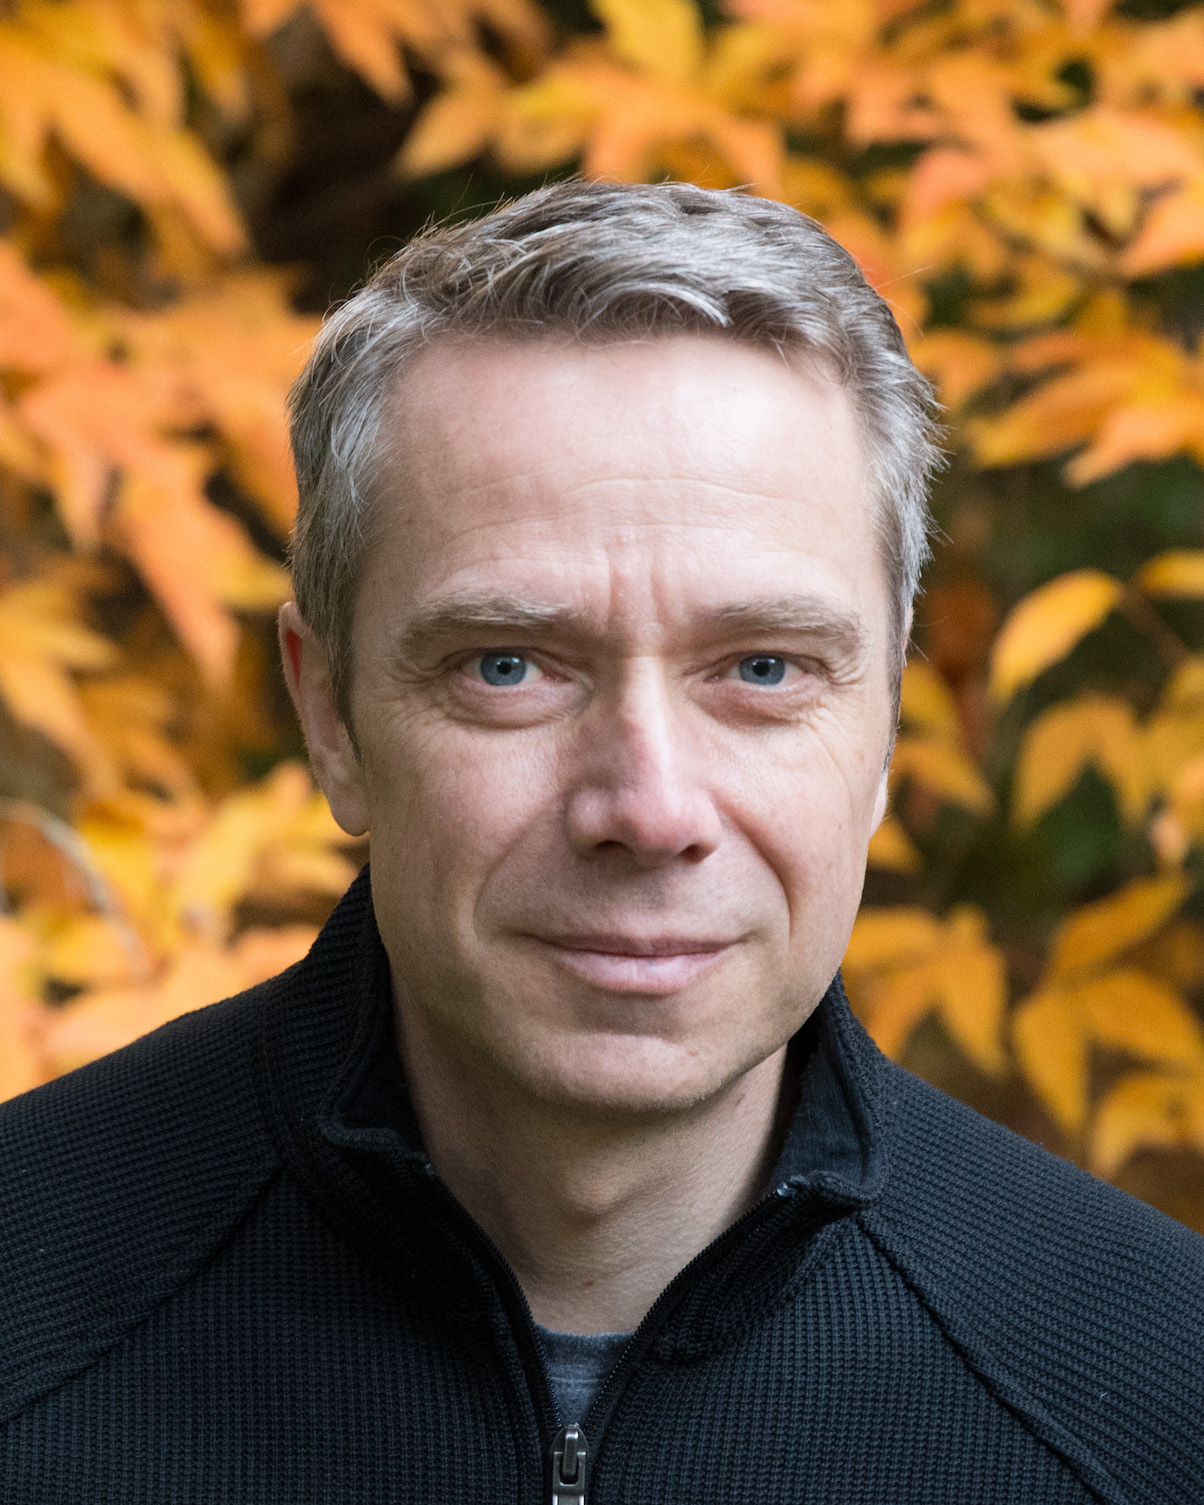
Invited Talk 2 (25 min + 5 min Q&A)
Dieter Fox
(Ai2 & UW)
Talk Title: “ToyBlocks: Enabling Controlled Experiments on
Robot Foundation Models”
|
| 9:35 – 9:45 | Sponsor Talk: Basis AI |
| 9:45 – 11:00 | Poster Session (overlaps with coffee break, 10:30 – 11:00) |
| 11:00 – 11:30 |
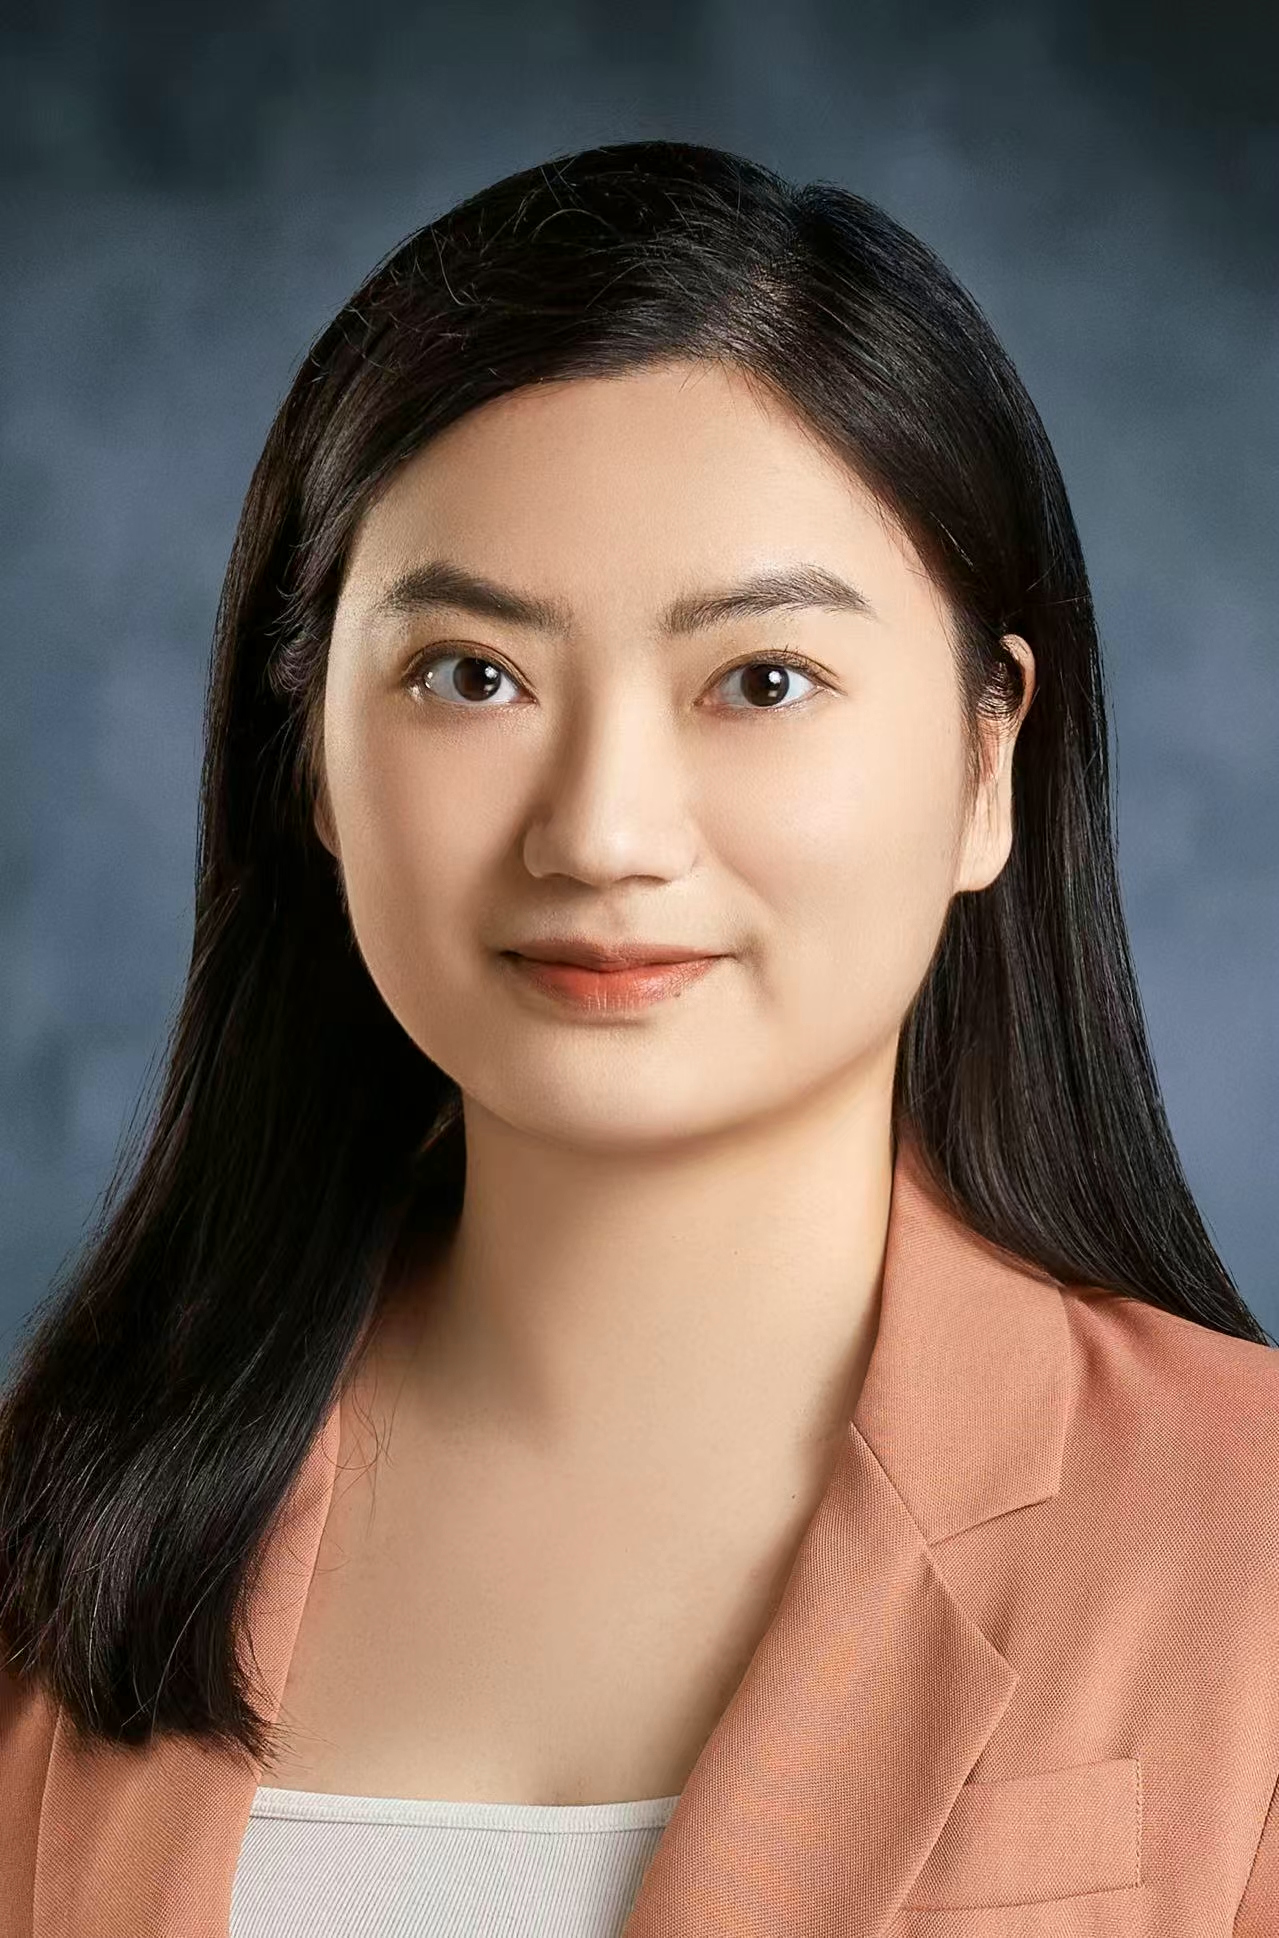
Invited Talk 3 (25 min + 5 min Q&A)
Panpan Cai
(Shanghai Jiao Tong U.)
Talk Title: “Learning Abstractions for Robot Planning in a
Big World”
|
| 11:30 – 12:00 |
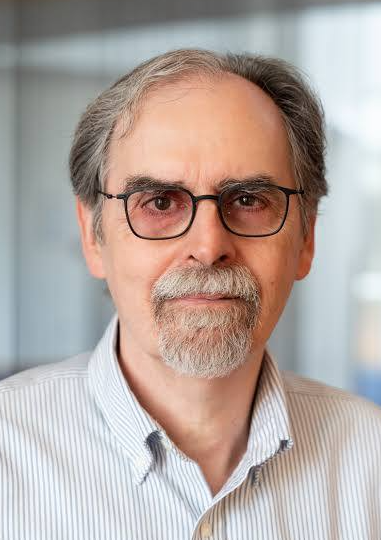
Invited Talk 4 (25 min + 5 min Q&A)
Tomás Lozano-Pérez
(MIT)
Talk Title: “Robot Programming”
|
| 12:00 – 12:25 | Panel Discussion & Introspection |
| 12:25 – 12:30 | Closing Remarks / Best Paper Awards |